Note 1
Vectors and Geometry
On my other notes on linear algebra, we discussed vectors and vector spaces in detail. However, I wish to discuss some parts again as linear algebra and multivariable calculus have different perspectives on how we view them. In this note, let’s discuss more on the geometric interpretation and less on abstractness of vector spaces.
1.1 Basic Terms and Intuitions
First, why should we even bother higher dimension for multivariable calculus? As the name suggests, multivariable calculus studies calculus over many variables. With generalization from the single variable calculus concepts, it is natural to consider planes and spaces of higher dimension. For instance, say we have a function \(f(x, y) = x + y\). We cannot graph this in the normal 2 dimensional Cartesian plane as we have two inputs and an output while the plane only has the space for two. As we have discussed in the notes for linear algebra, we can graph such functions in a 3 dimensional space.
The standard and conventional orientation of the 3D Cartesian Coordinate System is the Right-hand Rule. The orientation of the axis below follows the right-hand rule.
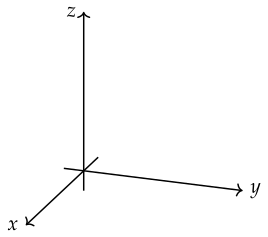
One way to memorize this is to have your curled right hand face up. Then, the direction where your hand is pointing is the direction of the \(x\)-axis and the direction of your thumb is the direction of the \(z\)-axis. This is a very common explanation; however, to be honest it is quite hard to remember for me. Another explanation that really helped me is to think of a clock at 3 P.M. The hour hand is the \(x\)-axis and the minute hand is the \(y\)-axis. Then, if you draw a line from the center of the clock pointing at you, that would be the \(z\)-axis.
Besides having the name 3-dimensional Cartesian coordinate system, it is often called as rectangular coordinate system for 3-space. When depicting a specific point, we will use the ordered triple \((x, y, z)\).
Some fun facts that we can notice from the notation is that we can represent \(x\), \(y\), and \(z\) axis as \(\{ (x, 0, 0) \mid x \in \mathbb {R} \}\), \(\{ (0, y, 0) \mid y \in \mathbb {R} \}\), and \(\{ (0, 0, z) \mid z \in \mathbb {R} \}\) respectively assuming that we only consider real numbers.
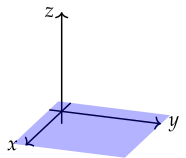
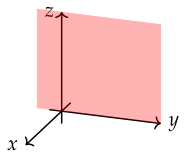
An extension of the idea above are planes perpendicular to an axis. We can see that the \(xy\)-plane, \(yz\)-plane, and \(zx\)-plane can be represented as the following.
\(xy\)-plane
\(\{ (x, y, 0) \mid x, y \in \mathbb {R} \}\)
\(yz\)-plane
\(\{ (0, y, z) \mid y, z \in \mathbb {R} \}\)
\(zx\)-plane
\(\{ (x, 0, z) \mid x, z \in \mathbb {R} \}\)
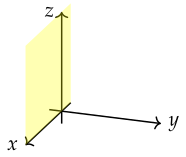
We can also notice that depending on what we have in the place for \(0\), we can have the planes \(x = a\), \(y = b\), and \(z = c\).
One other extension that we can have from 2D plane is the distance formula between two points.
Theorem 1.1.1: Distance Formula
The distance between two points \((x_1, y_1, z_1)\) and \((x_2, y_2, z_2)\) on a 3D plane can be represented as the following equation. \[ d = \sqrt { (x_2 - x_1)^2 + (y_2 - y_1)^2 + (z_2 - z_1)^2 } \]
Proof.
First, construct a right triangle with the points \(A(x_1, y_1, z_1)\), \(B(x_2, y_2, z_2)\), and \(C(x_2, y_2, z_1)\). Notice that the length of \(BC = |z_2 - z_1|\) and the length of the segment \(AC = \sqrt {(x_2 - x_1)^2 + (y_2 - y_1)^2}\). Using the Pythagorean theorem, \begin{align*} d &= \sqrt { \left ( \sqrt {(x_2 - x_1)^2 + (y_2 - y_1)^2} \right )^2 + (z_2 - z_1)^2 } \\ &= \sqrt { (x_2 - x_1)^2 + (y_2 - y_1)^2 + (z_2 - z_1)^2 } \end{align*}
holds and the distance between the two points can be written as \(\sqrt { (x_2 - x_1)^2 + (y_2 - y_1)^2 + (z_2 - z_1)^2 }\).
Using this, we can define a sphere just as we do for circles.
1.1.1 Geometric Intuition in 3-Dimensions
Consider equations of the following form with constants \(G, H, I, J\). \[ x^2 + y^2 + z^2 + Gx + Hy + Iz + J = 0 \] Just as we use completing squares for circles, we can rewrite the equation above as the following form with constants \(a, b, c, K\). \[ (x - a)^2 + (y - b)^2 + (z - c)^2 = K \] Square rooting both sides, we obtain \[ \sqrt {(x - a)^2 + (y - b)^2 + (z - c)^2} = \sqrt {K} \] which is equivalent of saying the locus of points \((x, y, z)\) that is in the distance \(\sqrt {K}\) from \((a, b, c)\) by Theorem 1.1.1. Naturally, we can notice that if \(K > 0\), such sphere exists. If \(K = 0\), the equation has one solution and the graph is a single point. If \(K < 0\), there exists no such graph. Graphing a square with the center \((x_0, y_0, z_0)\) and radius \(r\), we can obtain the following by plotting the locus of \((x, y, z)\) that satisfy \((x - x_0)^2 + (y - y_0)^2 + (z - z_0)^2 = r^2\).

Now that we can graph spheres, how about equations with two variables? When you think about it, it is actually pretty simple since it is the same as graphing in 2 dimensional plane and stretching it with respect to the remaining axis. Such equations are known as cylindrical surface.

The graph above is \(z = x^2\). This is the same as graphing the quadratic function in \(xz\)-plane and making its copy across the \(y\)-axis.
Continuing with this intuition, we can implement the ideas with vectors.