0.1 Geometry in 3-Space
In this section of the note, we will discuss more geometric analysis in 3-space with vectors. I personally think it was very interesting to see different interpretations of vectors in 3-space because they could be very abstract, yet a fundamental component that helps analyzing geometry in 3-dimensions.
0.1.1 Lines in 3-Space
Continuing with our prior discussion on vectors, let’s discuss more on lines and planes in 3-space and how they relate to vectors.
First, the components of lines in the coordinate plane can be thought of as a point and a direction, which would be slope. Given a point that a line passes through and the slope, or direction, of the line, we can find the unique line. Similarly, we could do the same for 3-space. The direction in this case would be a nonzero vector. In other words, given a point and a nonzero vector parallel to the line, we can find the unique line.
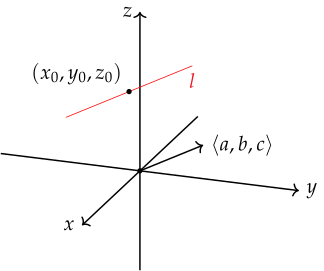
Looking at the graph above, we can derive a very important concept of representing lines in parametric equations.
A line \(l\) in 3-space that passes through the point \((x_0, y_0, z_0)\) and parallel to vector \(\mathbf {v} = \langle a, b, c \rangle \) can be represented as the following parametric equation for \(t \in (-\infty , \infty )\). \[ x = x_0 + at, \quad y = y_0 + bt, \quad z = z_0 + ct \]
To prove this, we can see that the line actually contains infinitely many vectors that passes through the point \((x_0, y_0, z_0)\) and \((x, y, z)\) while being parallel to \(\langle a, b, c \rangle \). In other words, \(\langle x - x_0, y - y_0, z - z_0 \rangle = t\mathbf {v} = \langle ta, tb, tc \rangle \) for some \(t\). Comparing the vectors element-wise, we obtain the parametric equation.
Another standard way of writing the parametric equation \(x = x_0 + at, y = y_0 + bt, z = z_0 + ct\) is the following. \[ \langle x, y, z \rangle = \langle x_0, y_0, z_0 \rangle + t \langle a, b, c \rangle \] This is known as a vector equation.
Let’s take a look at a quick example.
Exercise 0.1.1
Find a parametric equation and a vector equation of the line that passes through the point \((1, 2, 3)\) and parallel to \(\langle 1, 2, 3 \rangle \).
Solution.
Because the line passes through the point \((1, 2, 3)\) and is parallel to \(\langle 1, 2, 3 \rangle \), a vector equation can be written as \(\langle x, y, z \rangle = \langle 1, 2, 3 \rangle + t \langle 1, 2, 3 \rangle \). Similarly, a parametric equation can be written as \(x = 1 + t\), \(y = 2 + 2t\), and \(z = 3 + 3t\).
However, this is not the only answer. Because the line is also parallel to \(\langle 1, 2, 3 \rangle \), it is also parallel to \(\langle 2, 4, 6 \rangle \). Using this instead, we get a vector equation \(\langle 1, 2, 3 \rangle + t \langle 2, 4, 6 \rangle \). This shows that there are different parametrizations and vector equations for a given line.
One way vector equation can be very helpful than parametric equation is that we can directly see if two lines are parallel to each other. If the two vectors that are being scaled by \(t\) are scale multiples of each other, then the two lines are similar. This observation also leads us to define as new term.
Definition 0.1.2
The skew lines are two lines in 3-space that are not parallel to each other and that do not intersect.
Unlike 2-space, we can see that not being parallel does not necessarily imply that the two lines intersect.
Segments are very similar to lines. When we have to obtain a segment, then we can just limit our parameter \(t\) from the line obtained from the methods above.
Now that we have took a look at the lines in 3-space, let’s discuss its extension: planes.
0.1.2 Planes in 3-Space
First, let’s define the terms perpendicular and parallel in the context of planes.
Definition 0.1.3
A plane \(A\) and a vector \(\mathbf {v}\) are perpendicular if any vector lying on the plane \(A\) is orthogonal to \(\mathbf {v}\). Moreover, if there exists a vector that is perpendicular to two planes, then the planes are parallel. Finally, a vector and a plane is parallel if some normal vector of the plane is orthogonal to the vector.
Similar to how we found vector equations of a line, we could extend our understandings on plane.
The plane in 3-space that is perpendicular to a nonzero vector \(\mathbf {v} = \langle a, b, c \rangle \) and contains the point \((x_0, y_0, z_0)\) can be represented as the following equation. \[ a(x - x_0) + b(y - y_0) + c(z - z_0) = 0 \] Such vectors \(\mathbf {v}\) that are perpendicular to the plane are known as normal vectors. Moreover, the equation above is called the point-normal form.
Similar to how we defined a line, we can notice that the plane contains all vectors \(\langle x - x_0, y - y_0, z - z_0 \rangle \) that is perpendicular to \(\mathbf {v}\). Therefore using the dot product, we know that the vectors are orthogonal if and only if their dot product is zero. \[ \langle x - x_0, y - y_0, z - z_0 \rangle \cdot \langle a, b, c \rangle = 0 \] Expanding the equation, we obtain the equations of a plane. Besides this point-normal form of the equation of the plane, we obtain the following form by expanding. \[ ax + by + cz + d = 0 \] Here, \(d = -ax_0 - by_0 - cz_0\) and the from above is called the general form. Continuing, we can establish an important theorem on the general form.
Theorem 0.1.4
For a plane \(ax + by + cz + d = 0\) with \(\langle a, b, c \rangle \neq \langle 0, 0, 0 \rangle \), the normal vector is \(\langle a, b, c \rangle \).
Proof.
First, consider the case when \(a \neq 0\). Rearranging the equation, \[ ax + by + cz + d = a \left ( x + \frac {d}{a} \right ) + by + cz \] is obtained and \(a \left ( x + \frac {d}{a} \right ) + by + cz = 0\), which represents the plane with the normal vector \(\langle a, b, c \rangle \) and passes through the point \((-\frac {d}{a}, 0, 0)\). The case when \(b \neq 0\) or \(c \neq 0\) is proven in analogous way. Lastly, if all \(a, b, c\) are nonzero, then it is a plane that is shifted from the origin.
Let’s take a look at quick example.
Exercise 0.1.5
Find the equation of the plane that contains \(\langle 1, 2, 3 \rangle \) and perpendicular to \(\langle 1, 2, 3 \rangle \) in point-normal form and in general form.
Solution.
Using the form \(a(x - x_0) + b(y - y_0) + c(z - z_0) = 0\), the equation of the plane can be represented as \((x - 1) + 2(y - 2) + 3(z - 3) = 0\), or \(x + 2y + 3z - 14 = 0\).
Similar to lines, there can be multiple representations of the same plane. Now before we move on to curves, let’s discuss few meaningful geometric interpretations of planes.
The two cases that we will check are the angle between two planes and the distance between two parallel planes.
Definition 0.1.6
The smaller angle between two planes are known as the acute angle of intersection between the two planes.
I know we have the term “acute” in it, but \(\frac {\pi }{2}\) is included as acute angle of intersection if the two planes make a right angle. Now to find an interesting equation like Theorem ??, let’s prove a lemma.
Lemma 0.1.7
For two intersecting lines \(L_A\) and \(L_B\) in 3-space, let \(\theta \) be \(\angle (L_A, L_B)\). If \(n_A\) and \(n_B\) are vectors that are parallel to the lines respectively, then the following equation holds. \[ \cos \theta = \frac {| n_A \cdot n_B |}{\| n_A \| \| n_B \|} \]
Proof.
Let \(\alpha \) be the angle between \(n_A\) and \(n_B\). If \(0 < \alpha < \frac {\pi }{2}\), then the following equation holds by Theorem ??. \[ \cos \theta = \cos \alpha = \frac {n_A \cdot n_B}{\| n_A \| \| n_B \|} = \frac {| n_A \cdot n_B |}{\| n_A \| \| n_B \|} \] Similarly, consider the case when \(\frac {\pi }{2} \leq \alpha < \pi \). By the property of cosine functions, the following equation holds. \[ \cos \theta = -\cos \alpha = |\cos \alpha | = \frac {| n_A \cdot n_B |}{\| n_A \| \| n_B \|} \] Thus, the lemma holds.
With the lemma shown, we can derive an important theorem regarding the angle between two intersecting planes.
Theorem 0.1.8
For two intersecting planes \(A\) and \(B\) with normal vectors \(n_A\) and \(n_B\), if \(\theta \) is the acute angle of intersection between \(A\) and \(B\), then the following equation holds. \[ \cos \theta = \frac {| n_A \cdot n_B |}{\| n_A \| \| n_B \|} \]
Proof.
Let \(l_A\) and \(l_B\) be two lines normal to planes \(A\) and \(B\) respectively that also passes through the intersection of the planes. Let \(\alpha \) and \(\beta \) be the \(\angle (l_A, l_B)\) and \(\angle (l_B, A)\) respectively. Notice that \(\alpha + \beta = \frac {\pi }{2} = \beta + \theta \) through geometric interpretations. Therefore, \(\alpha = \theta \) and it suffices to find \(\cos \alpha \). Because the angle between \(l_A\) and \(l_B\) and the angle between \(n_A\) and \(n_B\) equal, the theorem holds by Lemma 0.1.8.
Continuing, let’s take a look at the case when two different planes do not intersect. To begin, consider the following theorem.
Theorem 0.1.9
For a plane \(ax + by + cz + d = 0\) and a point \((x_0, y_0, z_0)\), the distance \(D\) between the plane and the point is represented with the following formula. \[ D = \frac {| ax_0 + by_0 + cz_0 + d |}{\sqrt {a^2 + b^2 + c^2}} \]
Proof.
Let \(Q(x_1, y_1, z_1)\) be any point in the plane. If the angle between the normal vector \(\mathbf {n}\) of the plane from \(Q\) and the vector from \(Q\) to \(P\) is \(\theta \), then the distance \(D\) can be represented as \(\| \vec {QP} \| |\cos \theta |\). Thus, the following equations hold by Theorem ??. \[ D = \| \vec {QP} \| \cos \theta = \frac {\| \mathbf {n} \| \| \vec {QP} \| |\cos \theta |}{\| \mathbf {n} \|} = \frac {| \mathbf {n} \cdot \vec {QP} |}{\| \mathbf {n} \|} \] Defining \(\mathbf {n} = \langle a, b, c \rangle \), the following equations hold by construction. \begin{align*} | \mathbf {n} \cdot \vec {QP} | &= \left | \langle a, b, c \rangle \cdot \langle x_0 - x_1, y_0 - y_1, z_0 - z_1 \rangle \right | \\ &= | ax_0 + by_0 + cz_0 + d | \end{align*}
Because \(\| \mathbf {n} \| = \sqrt {a^2 + b^2 + c^2}\), the theorem satisfy.
Continuing from the theorem above, we could see that the distance between two planes is the distance between a plane and a point on the other plane. Note that both planes \(ax + by + cz + d_1 = 0\) and \(ax + by + cz + d_2 = 0\) are parallel. Therefore, the distance \(D\) between the two planes can be represented as the following by Theorem 0.1.9. \[ D = \frac {| ax_0 + by_0 + cz_0 + d_1 |}{\sqrt {a^2 + b^2 + c^2}} = \frac {| d_1 - d_2 |}{\sqrt {a^2 + b^2 + c^2}} \] Notice that this holds because \((x_0, y_0, z_0)\) lies on \(ax + by + cz + d_2 = 0\).
The distance \(D\) between two parallel planes \(ax + by + cz + d_1 = 0\) and \(ax + by + cz + d_2 = 0\) can be represented as the following. \[ D = \frac {| d_1 - d_2 |}{\sqrt {a^2 + b^2 + c^2}} \]
This is it for this part! In the next part, let’s continue from this linear ideas to expand them to curves.
0.1.3 Surfaces in 3-Space
Before we start graphing surfaces, let’s think about how we may achieve that. In the coordinate plane, we graph curves by knowing the locus of points that satisfy the given equation of a curve. Graphing surfaces is similar! In 3-space, we find which curves lie on the surface to find the general shape of a given surface.
Definition 0.1.10
The trace of the surface in a plane is the set of points of intersection of the surface and the plane.
Let’s take a look at an example. It is self-evident that the trace of a sphere in a plane is always a circle or a point assuming that they intersect. However for an algebraic approach, let’s forget how the surface \(S\) defined as \(x^2 + y^2 + z^2 = 9\) looks like. Given plane \(z = 2\), we can see that the trace of \(S\) in the plane \(z = 2\) can be found by substituting the value. In other words, \(S\) and the plane intersect if and only if \(z = 2\) and the trace is \(x^2 + y^2 = 5\). This trace is indeed a circle!

Continuing with this idea, we can try to construct the general shape of a surface by finding the traces. Let’s take a look at an example from our previous example.
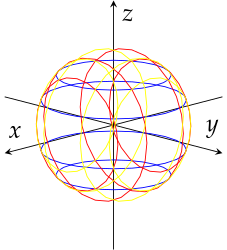
Continuing, here is another example.
Exercise 0.1.11
Find the general shape of the surface \(\frac {x^2}{36} - \frac {y^2}{9} + \frac {z^2}{4} = 1\).
Solution.
To find the general shape of the surface, we can try to find different traces in different planes to later combine them for a general shape.
First, let’s take a look at the traces in the plane \(x = k\). Substituting, we obtain an equation representing hyperbolas. \[ \frac {z^2}{4} - \frac {y^2}{9} = 1 - \frac {k^2}{36} \]
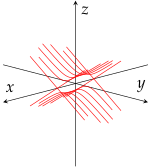
Continuing, let’s take a look at traces in the plane \(y = k\).
Substituting, we obtain \(\frac {x^2}{36} + \frac {z^2}{4} = 1 + \frac {k^2}{9}\). Rearranging the equation, the following equation of ellipse is obtained. \[ \frac {x^2}{36 \left ( 1 + \frac {k^2}{9} \right )} + \frac {z^2}{4 \left ( 1 + \frac {k^2}{9} \right )} = 1 \]
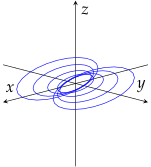
Finally for \(z = k\), we obtain the following equations just like the case for \(x = k\). \[ \frac {x^2}{36} - \frac {y^2}{9} = 1 - \frac {k^2}{4} \]
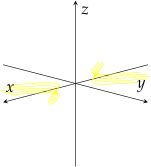
Combining the traces, we obtain the general shape of the surface.
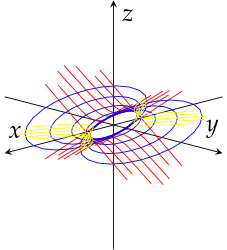

Such surfaces are known as hyperboloid. Continuing with surfaces, let’s discuss quadratic surfaces.
Note that in coordinate plane, we call equations of the form \[ Ax^2 + bxy + Cy^2 + Dx + Ey + F = 0 \] a conic section. Some examples include parabola, hyperbola, circle, and ellipse. Now, we could also generalize such equations in 3-space.
Definition 0.1.12
A quadric surface is known as the graph whose equation is of the following form. \[ Ax^2 + By^2 + Cz^2 + Dxy + Eyz + Fzx + Gx + Hy + Iz + J = 0 \]
For instance, the graph from our previous example is a quadric surface.
To investigate in some quadric surfaces, let’s take a look at few examples. First, consider the examples of the following form. \[ z^2 = \frac {x^2}{a^2} + \frac {y^2}{b^2} \] Considering the traces in planes \(z = k\), we can notice that the equation becomes \[ \frac {x^2}{a^2 k^2} + \frac {y^2}{b^2 k^2} = 1 \] which are ellipses or \((0, 0)\) if \(k = 0\).
Similarly for \(x = k\), we obtain \[ \frac {z^2}{\left ( \frac {k}{a} \right )^2} - \frac {y^2}{\left ( \frac {bk}{a} \right )^2} = 1 \] which are hyperbolas. Continuing for \(y = k\), we obtain the following equation for hyperbolas. \[ \frac {z^2}{\left ( \frac {k}{b} \right )^2} - \frac {x^2}{\left ( \frac {ak}{b} \right )^2} = 1 \] With the found traces, we could try finding the general shape of the surface by combining them.
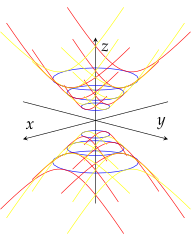

Such graphs are known as elliptic cone. Continuing, let’s try and graph surfaces of the following form with \(a, b > 0\). \[ y = \frac {x^2}{a^2} + \frac {z^2}{b^2} \] First, consider the trace in \(y = k\). Note that if \(k < 0\), then there are no points since right-hand side is sum of squares. Moreover rearranging the equations, we obtain the following equation for ellipses. \[ \frac {x^2}{ka^2} + \frac {z^2}{kb^2} = 1 \] Continuing, we can consider traces in \(x = k\) and \(z = k\). For each case, we can easily notice that it is the locus of quadratic functions of \(y\) with respect to \(x\) and \(z\). Graphing, we obtain the general sketch.
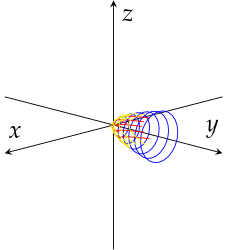

This is known as elliptic paraboloid. There are much more surfaces to discuss. For instance, hyperboloid of two sheets are represented by \(\frac {z^2}{c^2} - \frac {x^2}{a^2} - \frac {y^2}{b^2} = 1\) while hyperbolic paraboloid is described by \(\frac {z}{c} = \frac {x^2}{a^2} - \frac {y^2}{b^2}\). Moreover, ellipsoid are represented by \(\frac {x^2}{a^2} + \frac {y^2}{b^2} + \frac {z^2}{c^2} = 1\). For all such surfaces, the following fact holds.
Given a surface \(S\) with equation \(E(x, y, z)\), the equation of the surface \(S'\), obtained by translating \(S\) by \(a, b, c\) units in the \(x\), \(y\), and \(z\)-direction respectively, is \(E(x - a, y - b, z - c)\).
This is pretty straightforward with the same intuition we use for 2-space. This is it for this section! With different surfaces in mind, let’s discuss different ways to represent coordinates in 3-space.