Note 1
Vector-Valued Functions and Parametrization
In our previous note, we reviewed about vectors and their geometry. For calculus in higher dimension, we also study vector-valued functions in addition to real-valued ones that we discussed for calculus in 2-space. In this note, we will further extend our discussion on vectors with vector-valued functions, parametric curves, and calculus in higher dimension.
1.1 Vector-Valued Functions and Calculus
As always, let’s get started with the definition.
Definition 1.1.1
A function with real inputs is a vector-valued function if its outputs are vectors. The implicit domain is the largest set of reals for which the function is well-defined when the domain of a vector-valued function is not explicitly stated.
Below are some examples of vector-valued functions. \begin{align*} \mathbf {F}(t) &= \langle t + 2, 3t^2, 4t^3 \rangle , \quad -10 \leq t \leq 10 \\ \mathbf {r}(t) &= t \mathbf {i} + 5t \mathbf {j} + \cos t \mathbf {k}, \quad -2\pi \leq t \leq 10\pi \end{align*}
Note that the range need not be vectors in 3-space, but it could be any vectors. From the example above, we could define another term.
Definition 1.1.2
Consider a vector-valued function \(\mathbf {r} = f_1 (t) \mathbf {i} + f_2 (t) \mathbf {j} + f_3 (t) \mathbf {k}\). The functions \(f_1, f_2, f_3\) of \(t\) are known as the component functions of \(\mathbf {r}\).
Graphing such functions is pretty intuitive. For each input \(t\), we would draw the resulting vector from the origin, which is called the radius vector or position vector. Below is an example of graphing \(\mathbf {r} = \cos t \mathbf {i} + \sin t \mathbf {j} + t \mathbf {k}\) for \(t \in [-\pi , 2\pi ]\).
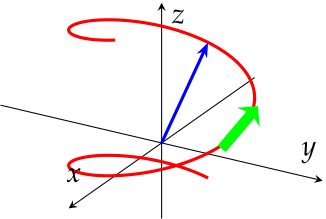
As you can see from the figure above, the blue arrow from the origin is a radius vector of the helix. The arrowhead on the curve is known as the orientation of the graph, which represents the direction in which the curve traverse as the input increase.
One more important thing to note is that the parametrization of a curve is not unique. For instance, the curve above \(\mathbf {r} = \cos t \mathbf {i} + \sin t \mathbf {j} + t \mathbf {k}\) for \(t \in [-\pi , 2\pi ]\) can also be represented as \(\mathbf {s} = \cos 2t \mathbf {i} + \sin 2t \mathbf {j} + 2t \mathbf {k}\) for \(t \in [-\frac {\pi }{2}, \pi ]\).
Extending our example, we can see that the curve also lies on an circular curve since for \(x(t) = \cos t\) and \(y(t) = \sin t\), \(x^2 + y^2 = 1\).
1.1.1 Calculus for Vector-Valued Functions
Now that we discussed what vector-valued functions are and how to graph them, it is natural to see how calculus work for such functions. Just like graphing, it is quite natural to see how calculus works given the properties of limits, derivatives, and integrals.
Given a vector-valued function \(\mathbf {r}(t) = f_1(t) \mathbf {i} + f_2(t) \mathbf {j} + f_3(t) \mathbf {k}\), its limits, derivative, and integrals are defined as the following.
- \(\displaystyle \lim _{t \to a} \mathbf {r}(t) = \left ( \lim _{t \to a} f_1(t) \right ) \mathbf {i} + \left ( \lim _{t \to a} f_2(t) \right ) \mathbf {j} + \left ( \lim _{t \to a} f_3(t) \right ) \mathbf {k}\)
- \(\mathbf {r}'(t) = f_1'(t) \mathbf {i} + f_2'(t) \mathbf {j} + f_3'(t) \mathbf {k}\)
- \(\displaystyle \int \mathbf {r}(t)\, dt = \int f_1(t)\, dt\ \mathbf {i} + \int f_2(t)\, dt\ \mathbf {j} + \int f_3(t)\, dt\ \mathbf {k}\)
- \(\displaystyle \int _{a}^{b} \mathbf {r}(t)\, dt = \int _{a}^{b} f_1(t)\, dt\ \mathbf {i} + \int _{a}^{b} f_2(t)\, dt\ \mathbf {j} + \int _{a}^{b} f_3(t)\, dt\ \mathbf {k}\)
Continuing with the definitions, it is natural to notice that the limit, derivatives, and integrals exist if and only if they exist for the component functions. In other words, \(\mathbf {r}\) is continuous at \(a\) if and only if its component functions are continuous at \(a\).
Using the definition and properties of derivatives and integrals for real-valued functions, it is self-evident that the following rules also hold for vector-valued functions \(\mathbf {r}\) under the appropriate conditions.
- \((k\mathbf {r})' = k\mathbf {r}'\)
- \((\mathbf {r_1} \pm \mathbf {r_2})'= \mathbf {r_1}' \pm \mathbf {r_2}'\)
- For real-valued function \(f\), \((f \cdot \mathbf {r})' = f' \cdot \mathbf {r} + f \cdot \mathbf {r}'\)
- \(\displaystyle \int k\mathbf {r}(t)\, dt = k \int \mathbf {r}(t)\, dt\)
- \(\displaystyle \int \mathbf {r_1}(t) \pm \mathbf {r_2}(t)\, dt = \int \mathbf {r_1}(t)\, dt \pm \int \mathbf {r_2}(t)\, dt\)
- For \(\mathbf {R}'(t) = \mathbf {r}(t)\) satisfying for \(t \in [a, b]\), \(\displaystyle \int _{a}^{b} \mathbf {r}(t)\, dt = \mathbf {R}(b) - \mathbf {R}(a)\)
Before concluding this section of the note, let’s discuss how we could geometrically interpret derivatives of vector-valued functions.
First, consider the following equations. \begin{align*} &\quad \ \mathbf {r}'(t) \\ &= f_1'(t) \mathbf {i} + f_2'(t) \mathbf {j} + f_3'(t) \mathbf {k} \\ &= \left ( \lim _{h \to 0} \frac {f_1(t + h) - f_1(t)}{h} \right ) \mathbf {i} + \left ( \lim _{h \to 0} \frac {f_2(t + h) - f_2(t)}{h} \right ) \mathbf {j} \\ &\qquad \qquad \qquad \qquad \qquad \qquad \qquad \qquad \quad + \left ( \lim _{h \to 0} \frac {f_3(t + h) - f_3(t)}{h} \right ) \mathbf {k} \\ &= \lim _{h \to 0} \frac {f_1(t + h) \mathbf {i} + f_2(t + h) \mathbf {j} + f_3(t + h) \mathbf {k} - \left ( f_1(t) \mathbf {i} + f_2(t) \mathbf {j} + f_3(t) \mathbf {k} \right ) }{h} \\ &= \lim _{h \to 0} \frac {\mathbf {r}(t + h) - \mathbf {r}(t)}{h} \end{align*}
From our equation, it is evident that \(\mathbf {r}'(t)\) is getting more parallel with line tangent to the curve at the terminal point of \(\mathbf {r}(t)\) as \(h \to 0\). In other words, \(\mathbf {r}'(t)\) is a vector that is tangent to the curve at \(r(t)\) for some value \(t\). Such vectors are called tangent vector and the line that passes through tangent vectors is known as tangent line. Let’s take a look at an example.
Exercise 1.1.3
Given \(\mathbf {r}(t) = \langle \frac {t^2}{2}, \sin t, e^t \rangle \), find the tangent vector and tangent line at \(t = \pi \).
Solution.
First, notice that \(\mathbf {r}'(t) = \langle t, \cos t, e^t \rangle \). Therefore, \(\mathbf {r}'(\pi ) = \langle \pi , -1, e^\pi \rangle \), which is the tangent vector.
Continuing, note that \(\mathbf {r}(\pi ) = \langle \frac {\pi ^2}{2}, 0, e^\pi \rangle \). Therefore, the tangent line can be represented as \(L(t) = \langle \frac {\pi ^2}{2}, 0, e^\pi \rangle + t \langle \pi , -1, e^\pi \rangle \).
Before concluding this section of the note, consider the following theorem.
Theorem 1.1.4
Given vector-valued functions \(\mathbf {r_1}\) and \(\mathbf {r_2}\), the following equations hold.
- \((\mathbf {r_1} \cdot \mathbf {r_2})' = \mathbf {r_1}' \cdot \mathbf {r_2} + \mathbf {r_1} \cdot \mathbf {r_2}'\)
- \((\mathbf {r_1} \times \mathbf {r_2})' = \mathbf {r_1}' \times \mathbf {r_2} + \mathbf {r_1} \times \mathbf {r_2}'\)
Proof.
For the first equation, it suffices to show for vectors in 3-space without loss of generality. Define \(\mathbf {r_1} = \langle f_1, g_1, h_1 \rangle \) and \(\mathbf {r_2} = \langle f_2, g_2, h_2 \rangle \). By definition, \(\mathbf {r_1} \cdot \mathbf {r_2} = f_1f_2 + g_1g_2 + h_1h_2\). Therefore, \((\mathbf {r_1} \cdot \mathbf {r_2})' = (f_1'f_2 + g_1'g_2 + h_1'h_2) + (f_1f_2' + g_1g_2' + h_1h_2')\), which is equal to \(\langle f_1', g_1', h_1' \rangle \cdot \langle f_2, g_2, h_2 \rangle + \langle f_1, g_1, h_1 \rangle \cdot \langle f_2', g_2', h_2' \rangle \). Thus, the first equation holds.
Note that the second equation holds for \(\mathbf {r_1}\) and \(\mathbf {r_2}\) in 3-space. Therefore, define \(\mathbf {r_1} = \langle f_1, g_1, h_1 \rangle \) and \(\mathbf {r_2} = \langle f_2, g_2, h_2 \rangle \). Consider the following equations. \begin{align*} \mathbf {r_1} \times \mathbf {r_2} &= \langle g_1h_2 - h_1g_2, h_1f_2 - f_1h_2, f_1g_2 - g_1f_2 \rangle \\ (\mathbf {r_1} \times \mathbf {r_2})' &= \langle g_1'h_2 - h_1'g_2 + g_1h_2' - h_1g_2', h_1'f_2 - f_1'h_2 \\ &\qquad \qquad \qquad \quad + h_1f_2' - f_1h_2', f_1'g_2 - g_1'f_2 + f_1g_2' - g_1f_2' \rangle \\ &= \langle g_1'h_2 - h_1'g_2, h_1'f_2 - f_1'h_2, f_1'g_2 - g_1'f_2 \rangle \\ &\qquad \qquad \qquad \quad + \langle g_1h_2' - h_1g_2', h_1f_2' - f_1h_2', f_1g_2' - g_1f_2' \rangle \\ &= \mathbf {r_1}' \times \mathbf {r_2} + \mathbf {r_1} \times \mathbf {r_2}' \end{align*}
Thus, the theorem holds.
One fun fact that we can notice from the first equation is that if we assume \(\mathbf {r}(t) \cdot \mathbf {r}(t) = a\) for some constant \(a\), then \(\mathbf {r}'(t) \cdot \mathbf {r}(t) + \mathbf {r}(t) \cdot \mathbf {r}'(t) = 0\) and \(\mathbf {r}(t) \cdot \mathbf {r}'(t) = 0\). In other words, \(\mathbf {r}(t)\) and \(\mathbf {r}'(t)\) are orthogonal! This is it for this section, and let’s discuss more on parametrization in the next section.